Hi there  Welcome to my Homepage!
I am a PhD student at  MMLab@HKU (2026.9 - 2030.8), advised by Prof. Xihui Liu. I founded IAAI, and currently intern at Tencent LightSpeed.
I received my B.Eng. from Xidian University (2022.9 - 2026.6). During my studies, I interned at ByteDance Seed and was an RA at MVIG@SJTU with Prof. Lixin Yang and Prof. Cewu Lu.
News
- Internship completed
Experience
The University of Hong Kong Sep 2026 - Phd at MMLab@HKU
Tencent IEG Sep 2026 - Talent Prog. Intern at LightSpeed
ByteDance Seed Oct 2025 - May 2026 Research Intern at Seed-Robotics
Astribot Inc. June 2025 - Sep 2025 Research Intern with Jianan Wang
Shanghai Jiao Tong University July 2024 - June 2025 Research Assistant at MVIG Lab
湖北省武昌实验中学 Sep 2019 - June 2022 那是一段小有遗憾的幸福时光.
Works
OneWM: Can World and Action Modeling Benefit Each Other under Unified Causal Training?
*, Bokai Lin*, Xinkai Wang*, Chubin Zhang, Xiangnan Wu, Kuan Zhang, Weiyang Jin, Jiwen Yu, Yiming Li, Cewu Lu, Lixin Yang†, Xihui Liu†
OneWM unifies world prediction and action learning for mutual benefit. Its “Endless Dream” continues in imagination without new observations.
*, Bokai Lin*, Xinkai Wang*, Chubin Zhang, Xiangnan Wu, Kuan Zhang, Weiyang Jin, Jiwen Yu, Yiming Li, Cewu Lu, Lixin Yang†, Xihui Liu†
OneWM unifies world prediction and action learning for mutual benefit. Its “Endless Dream” continues in imagination without new observations.
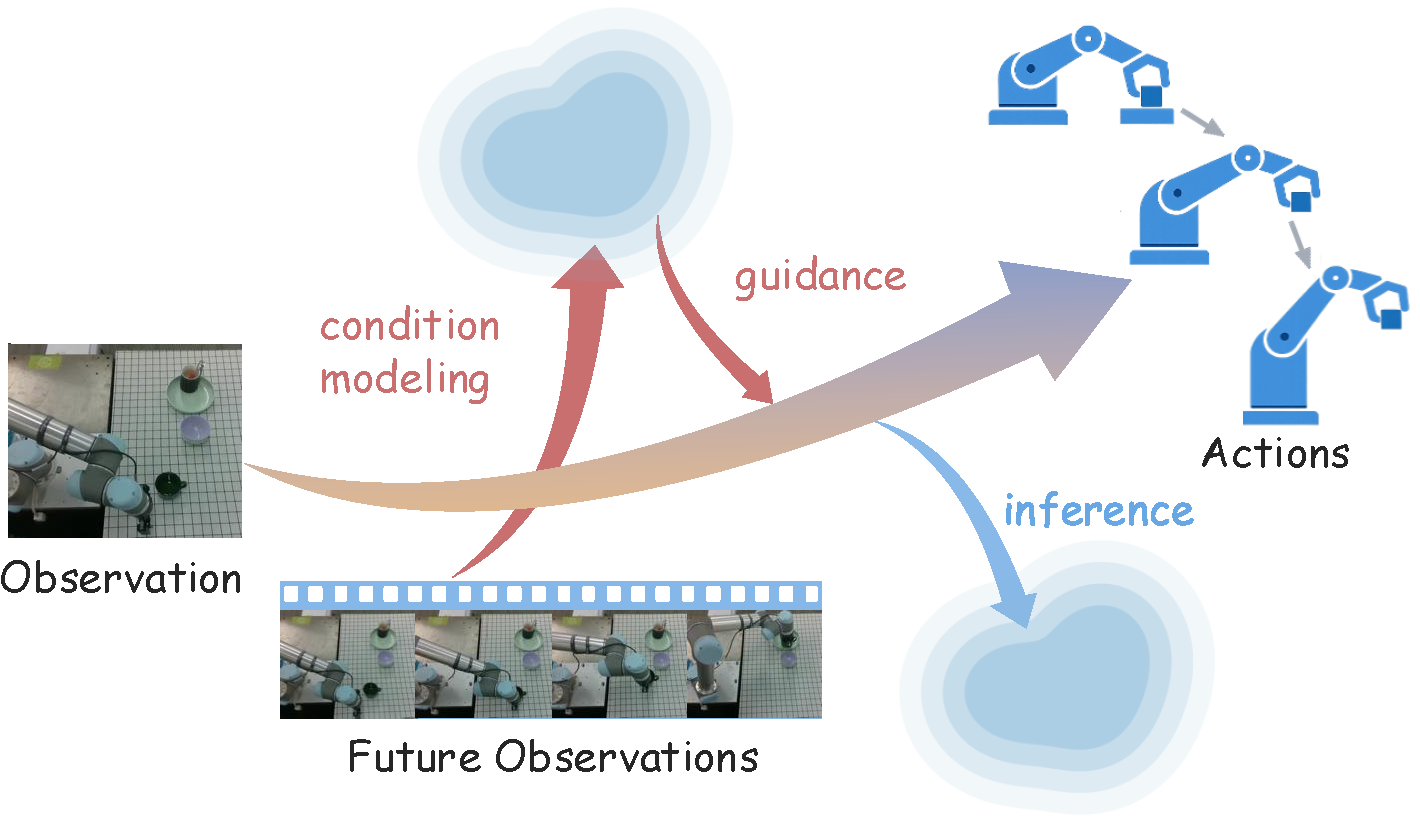
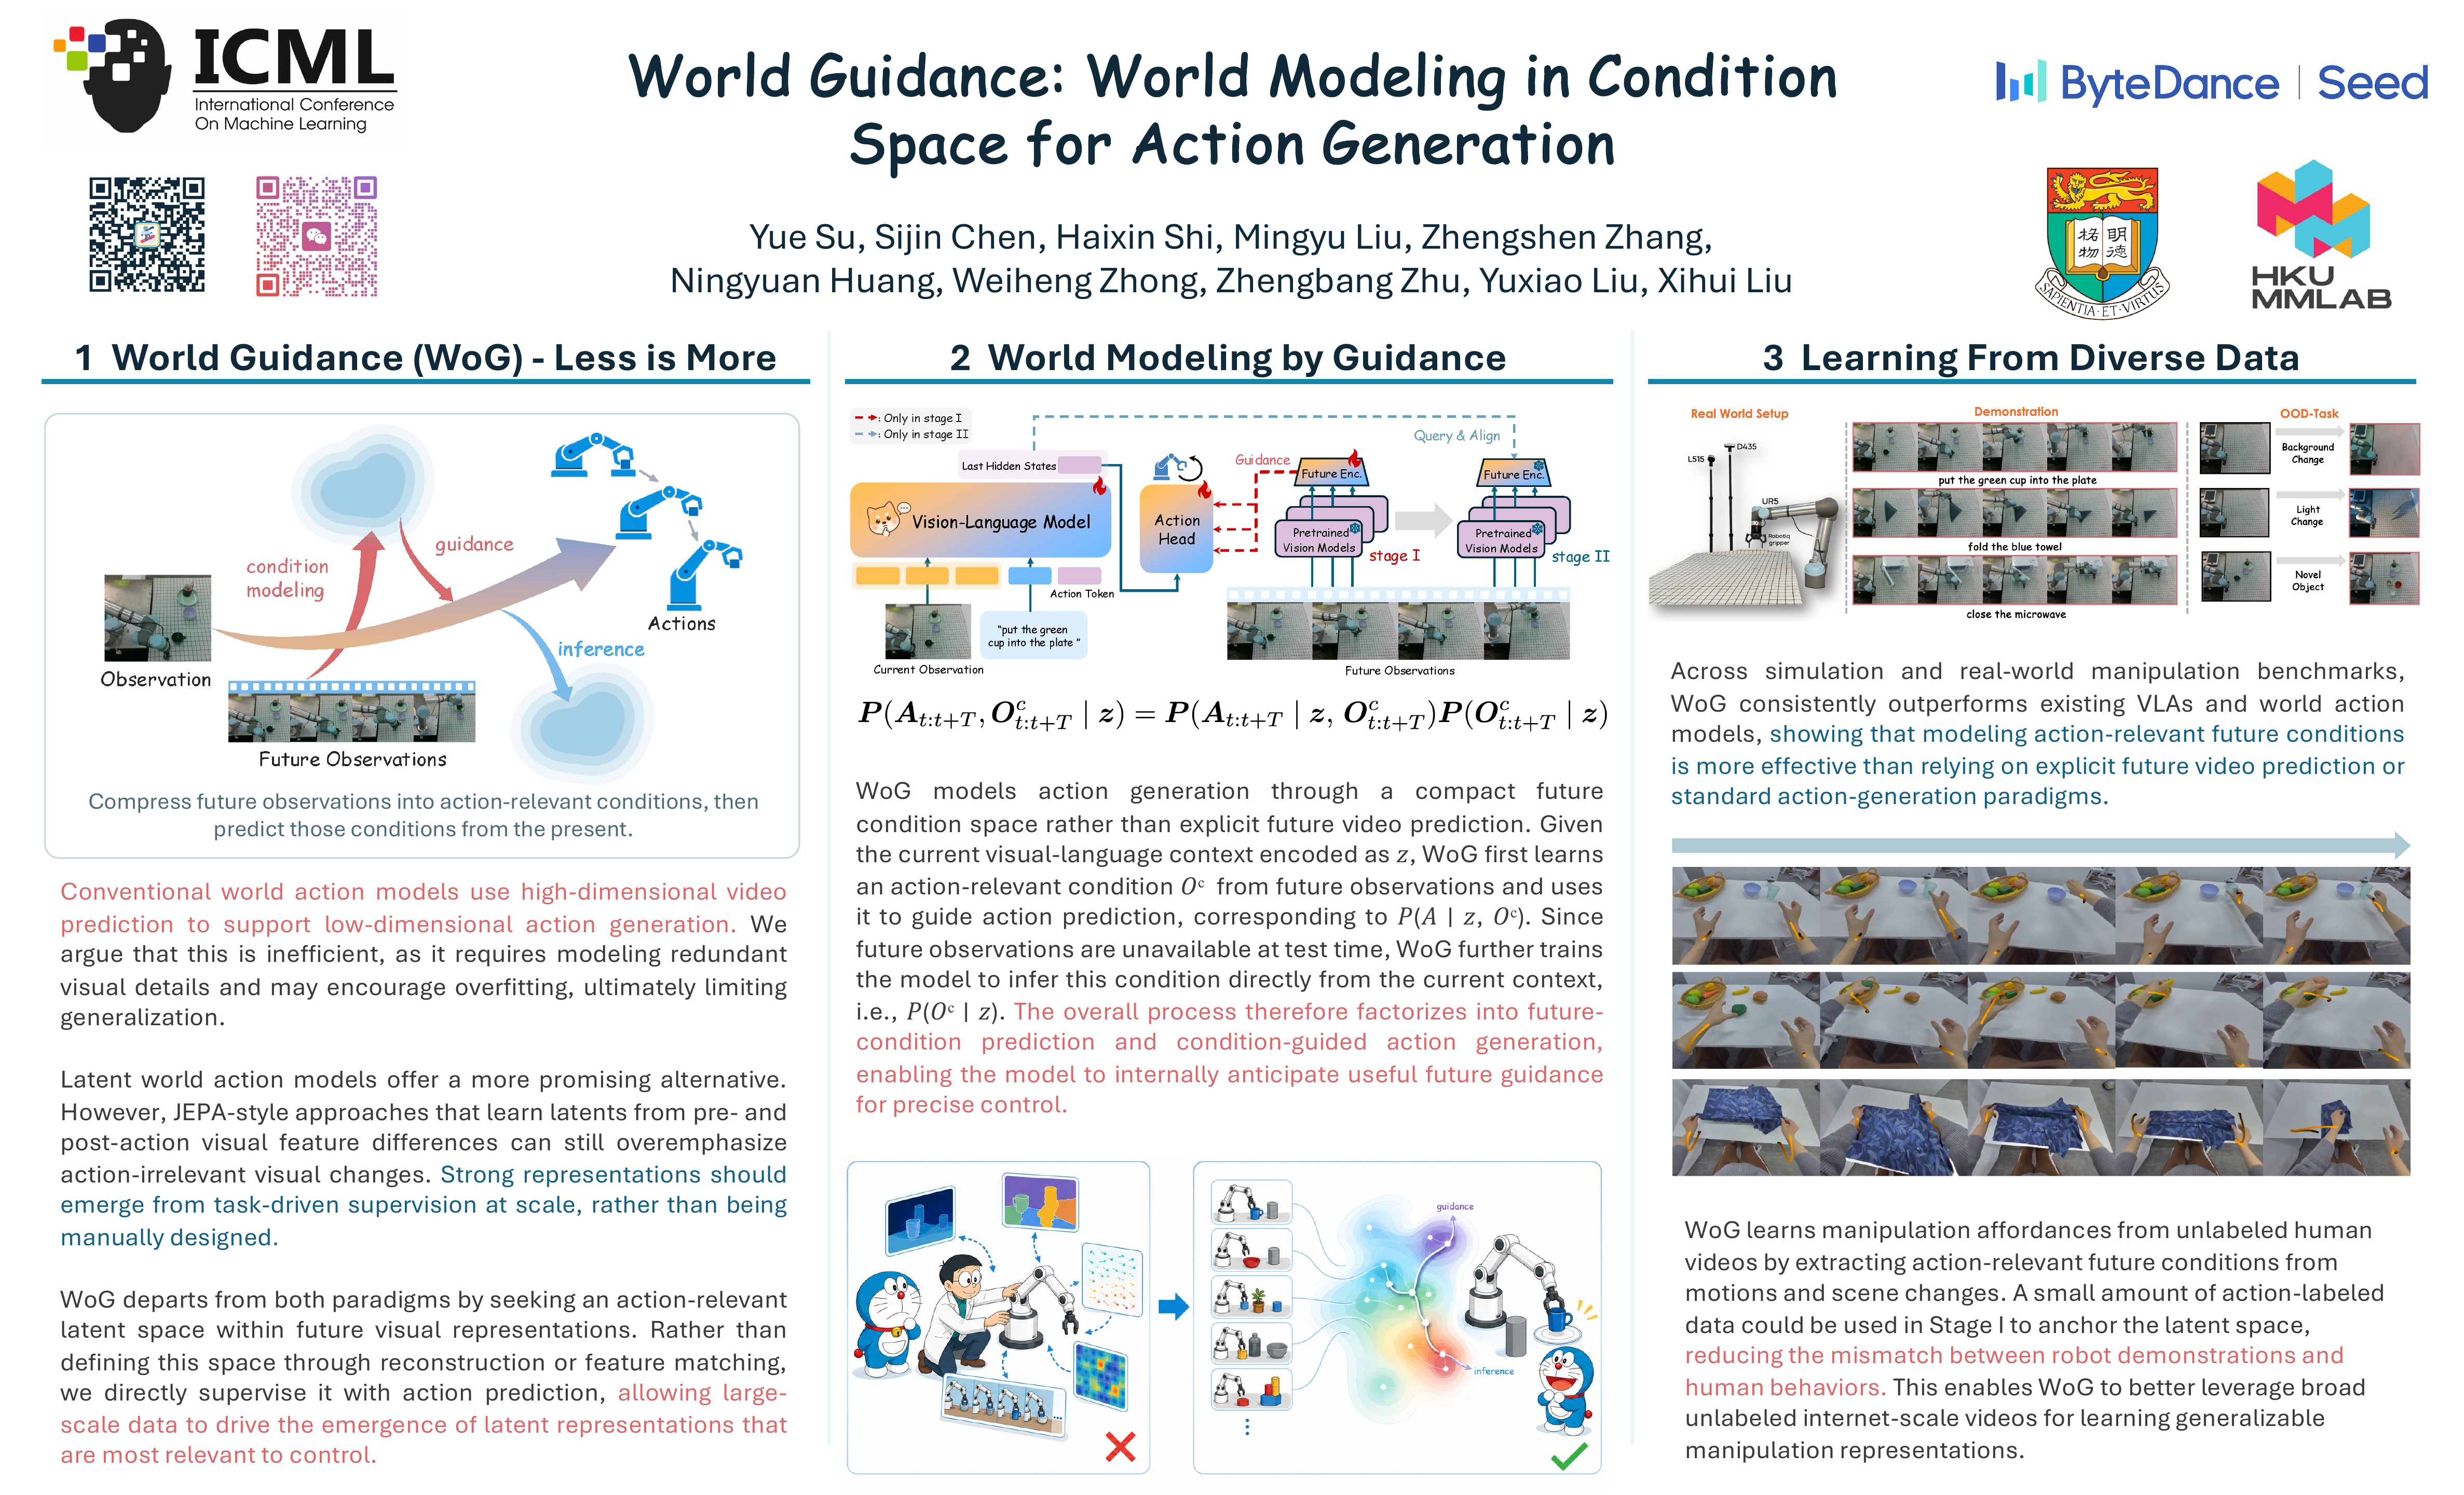
World Guidance: World Modeling in Condition Space for Action Generation
, Sijin Chen, Haixin Shi, Mingyu Liu, Zhengshen Zhang, Ningyuan Huang, Weiheng Zhong, Zhengbang Zhu, Yuxiao Liu†, Xihui Liu†
We propose WoG (World Guidance), a world modeling paradigm in condition space for action generation: less is more.
, Sijin Chen, Haixin Shi, Mingyu Liu, Zhengshen Zhang, Ningyuan Huang, Weiheng Zhong, Zhengbang Zhu, Yuxiao Liu†, Xihui Liu†
We propose WoG (World Guidance), a world modeling paradigm in condition space for action generation: less is more.
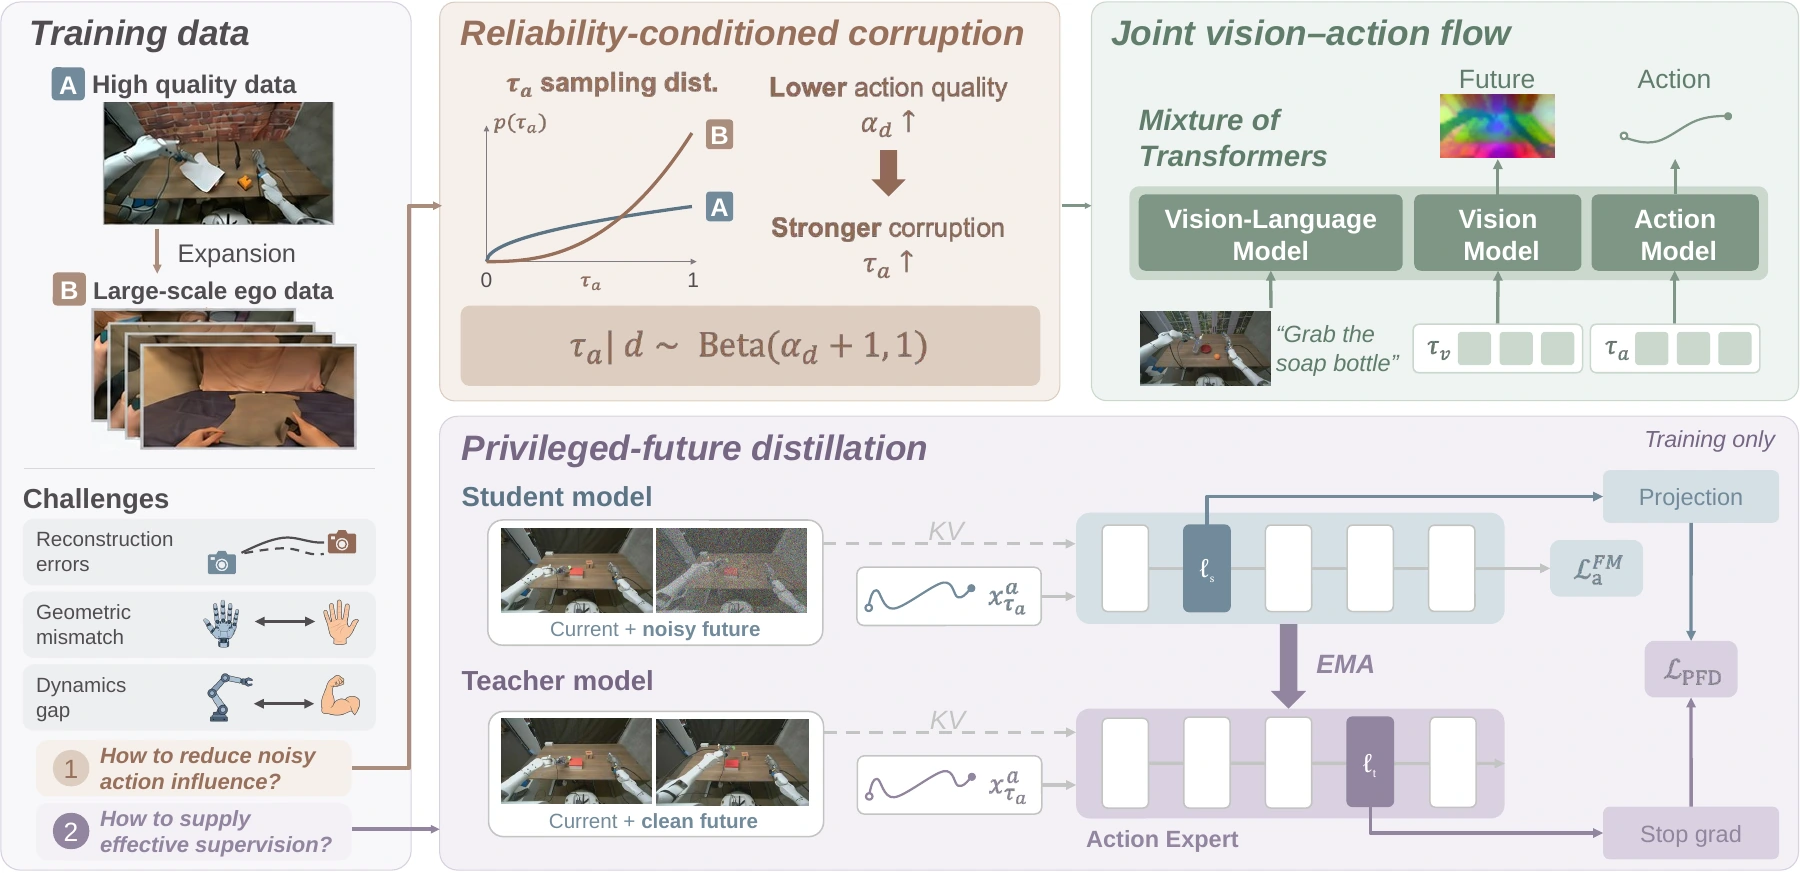
EgoForesight: Effectively Scaling Policy Learning with Noisy Egocentric Actions
Chubin Zhang, Changyuan Wang, Yirui Wang, Ao Li, Shilin Ma, , Cai Zhou, Xiuwei Xu, Tianle Zhang, Yansong Tang†
EgoForesight scales robot policy learning with noisy egocentric actions through reliability-aware supervision and privileged-future representation distillation.
Chubin Zhang, Changyuan Wang, Yirui Wang, Ao Li, Shilin Ma, , Cai Zhou, Xiuwei Xu, Tianle Zhang, Yansong Tang†
EgoForesight scales robot policy learning with noisy egocentric actions through reliability-aware supervision and privileged-future representation distillation.
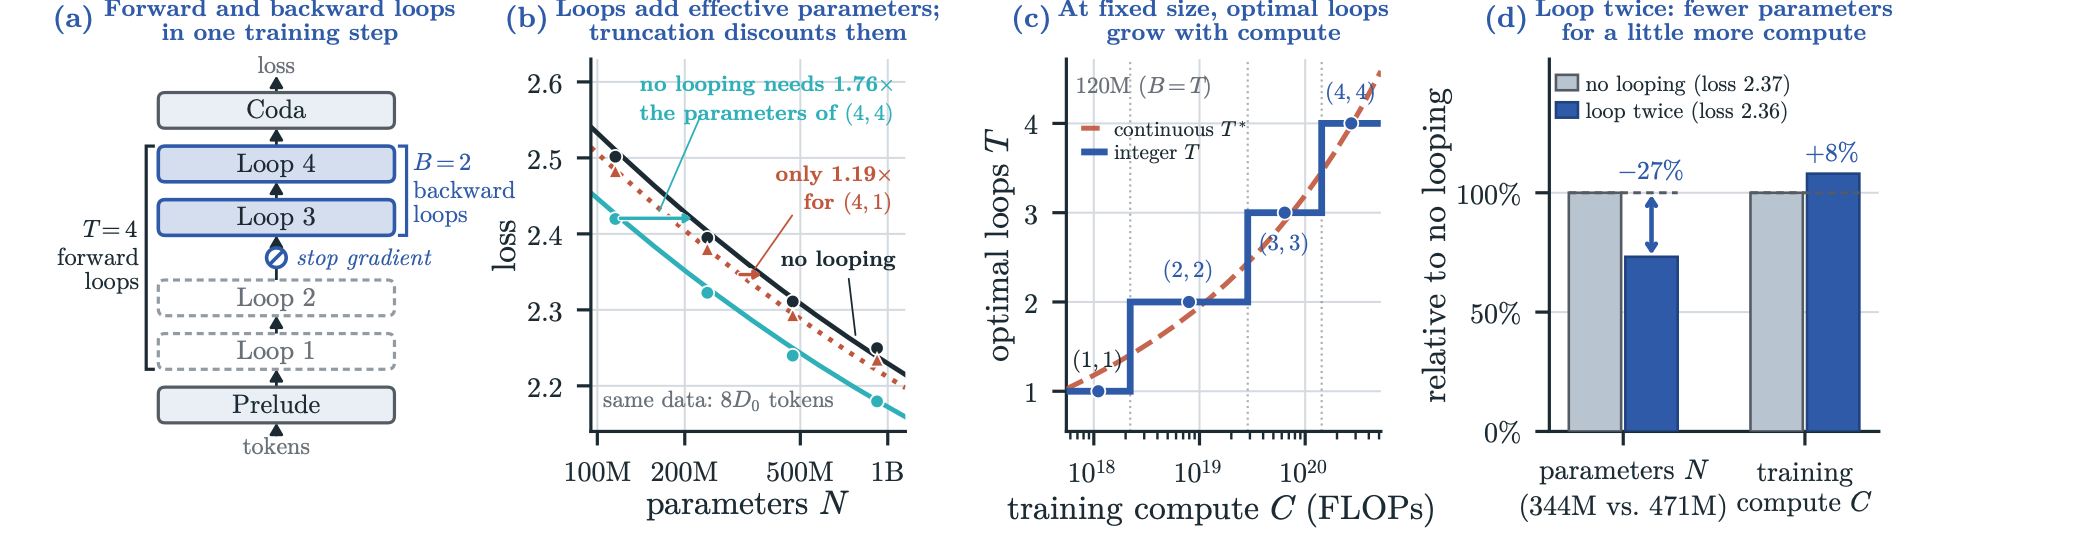
Truncate or Not? A Scaling Study of Looped Transformers with Truncated Backpropagation
Xuyuan Xiong*, Siyu Chen*, Zihan Shao, , Weiyang Jin, Ping Luo, Zhuoran Yang†, Xihui Liu†
A unified scaling law over nearly 600 runs favors full BPTT through fewer loops, and two fully trained loops beat a larger non-looped model with fewer parameters.
Xuyuan Xiong*, Siyu Chen*, Zihan Shao, , Weiyang Jin, Ping Luo, Zhuoran Yang†, Xihui Liu†
A unified scaling law over nearly 600 runs favors full BPTT through fewer loops, and two fully trained loops beat a larger non-looped model with fewer parameters.
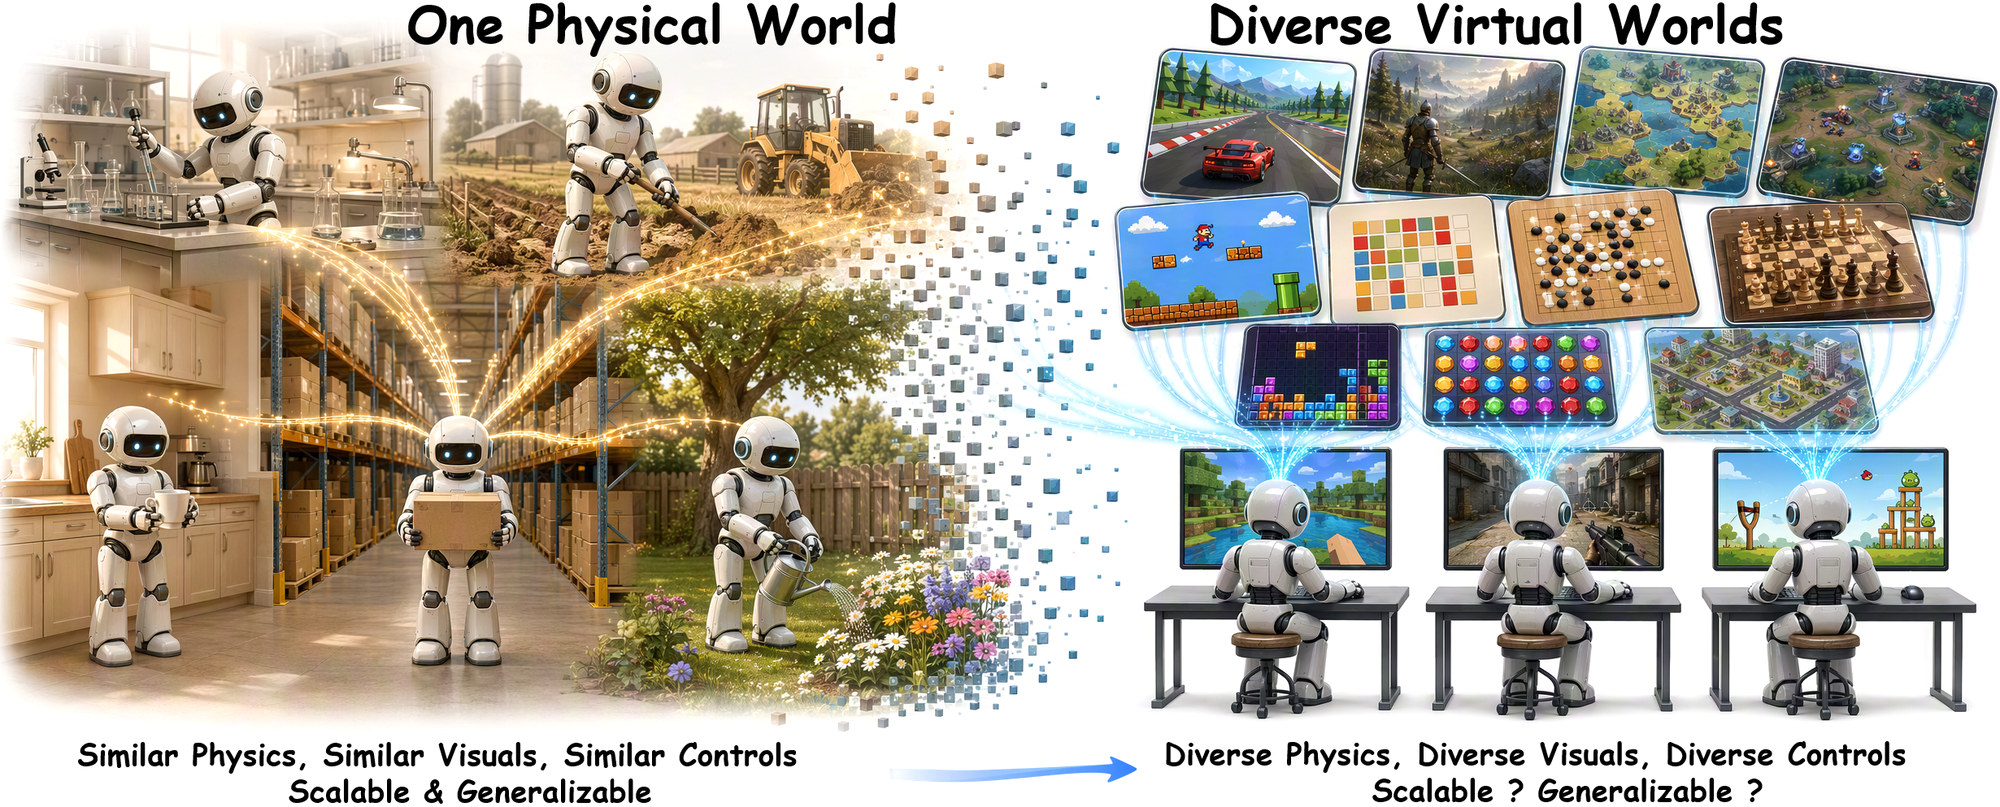
Scaling in Games: Continued Pre-Training for Embodied Agents in Diverse Virtual Worlds
Kuan Zhang*, Yukun Chen*, Zhihao Yang*, , Xiangnan Wu, Zirong Chen, Run Luo, Jinkun Hou, Tao Tan, Yinhe Zheng†, Yiming Li†
A controlled study of how gameplay data, world diversity, and model size scale continued pre-training and cross-world generalization for embodied game agents.
Kuan Zhang*, Yukun Chen*, Zhihao Yang*, , Xiangnan Wu, Zirong Chen, Run Luo, Jinkun Hou, Tao Tan, Yinhe Zheng†, Yiming Li†
A controlled study of how gameplay data, world diversity, and model size scale continued pre-training and cross-world generalization for embodied game agents.
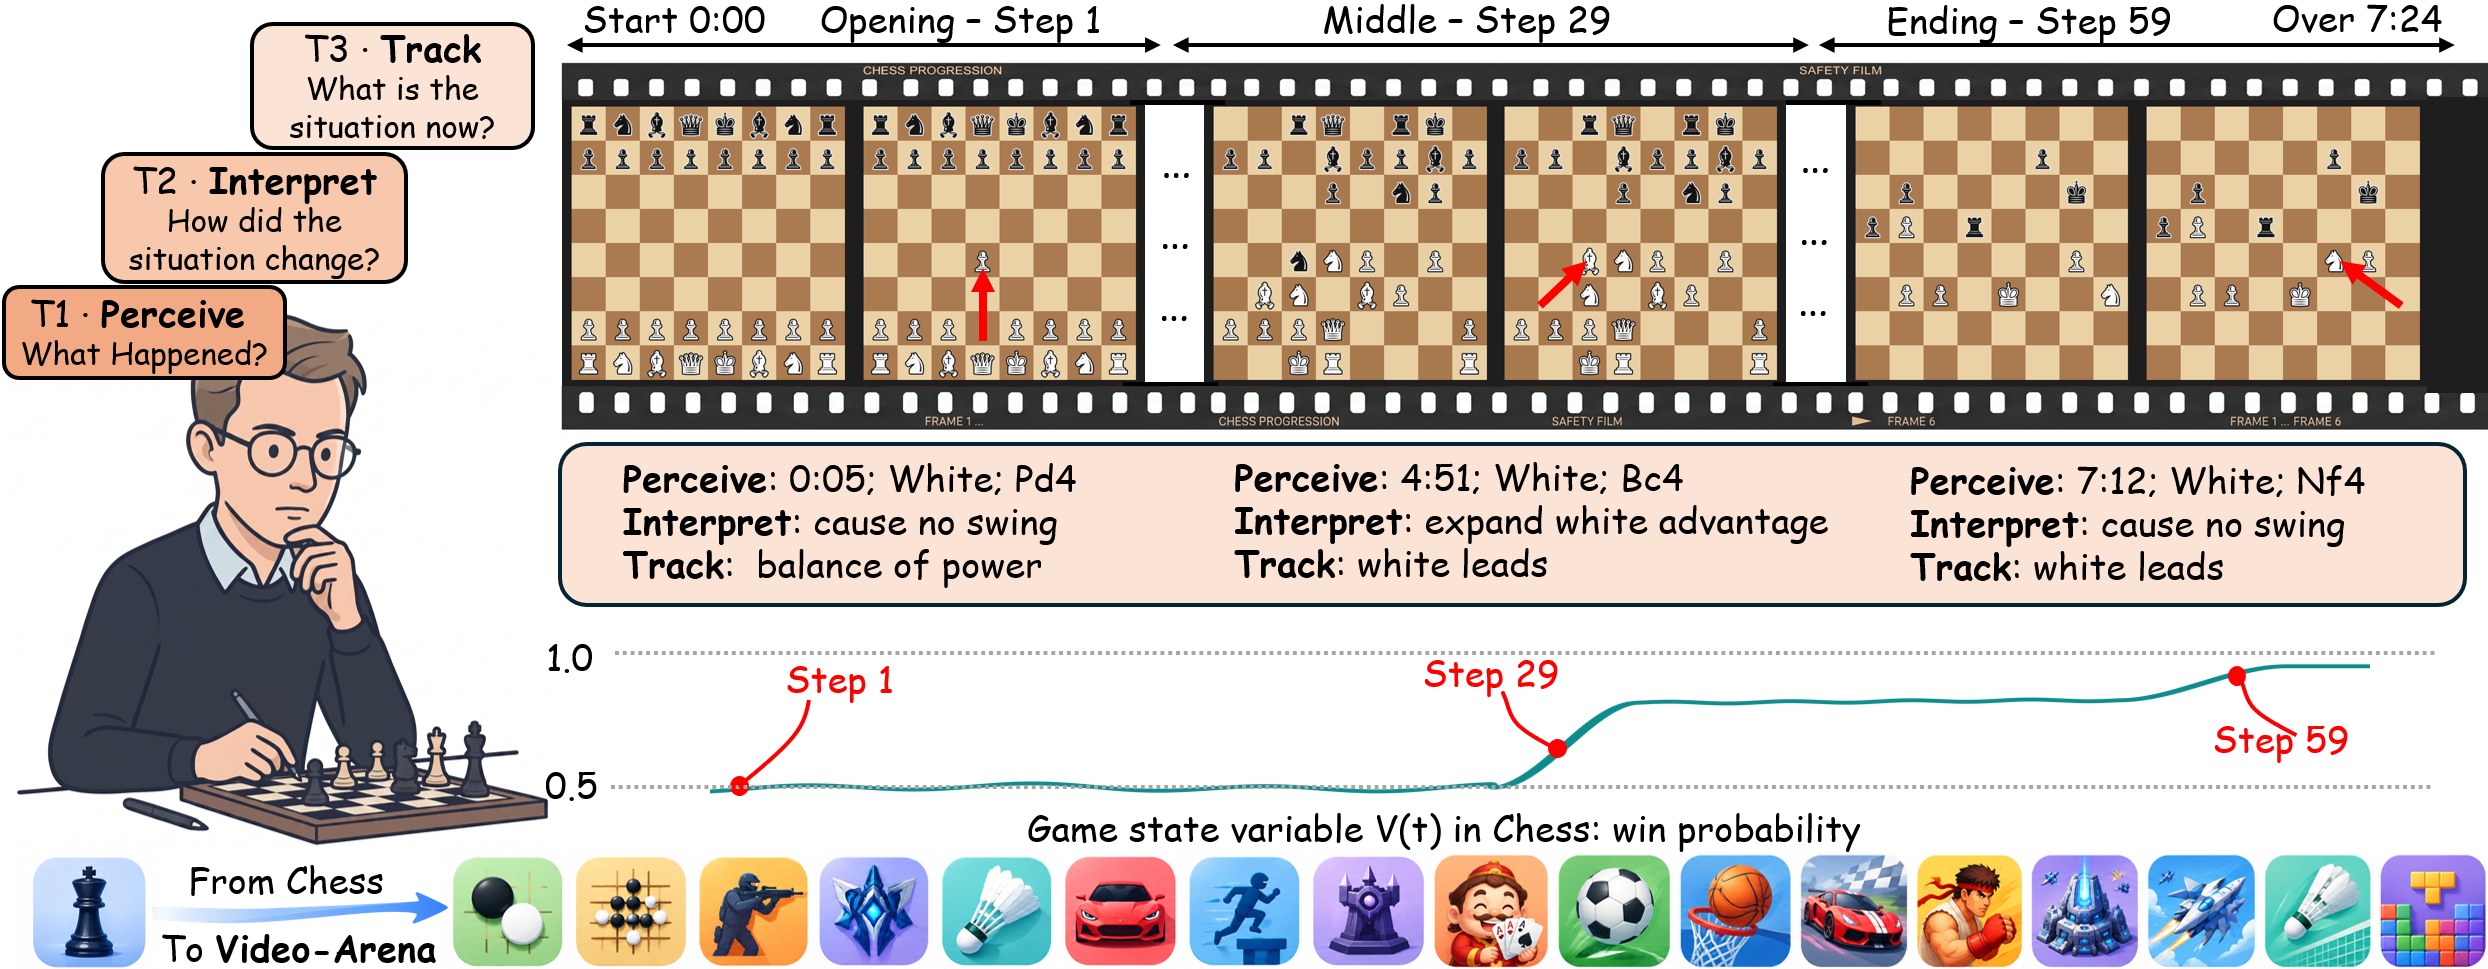
Video-Arena: A Scalable Agentic Video Benchmark for Spatiotemporal Capability
Kuan Zhang*, Yukun Chen*, Zhihao Yang*, , Xiangnan Wu, Zirong Chen, Run Luo, Tao Tan, Yinhe Zheng†, Yiming Li†
A scalable video benchmark for perceiving critical events, interpreting state updates, and tracking evolving world states under visual and agentic evaluation protocols.
Kuan Zhang*, Yukun Chen*, Zhihao Yang*, , Xiangnan Wu, Zirong Chen, Run Luo, Tao Tan, Yinhe Zheng†, Yiming Li†
A scalable video benchmark for perceiving critical events, interpreting state updates, and tracking evolving world states under visual and agentic evaluation protocols.
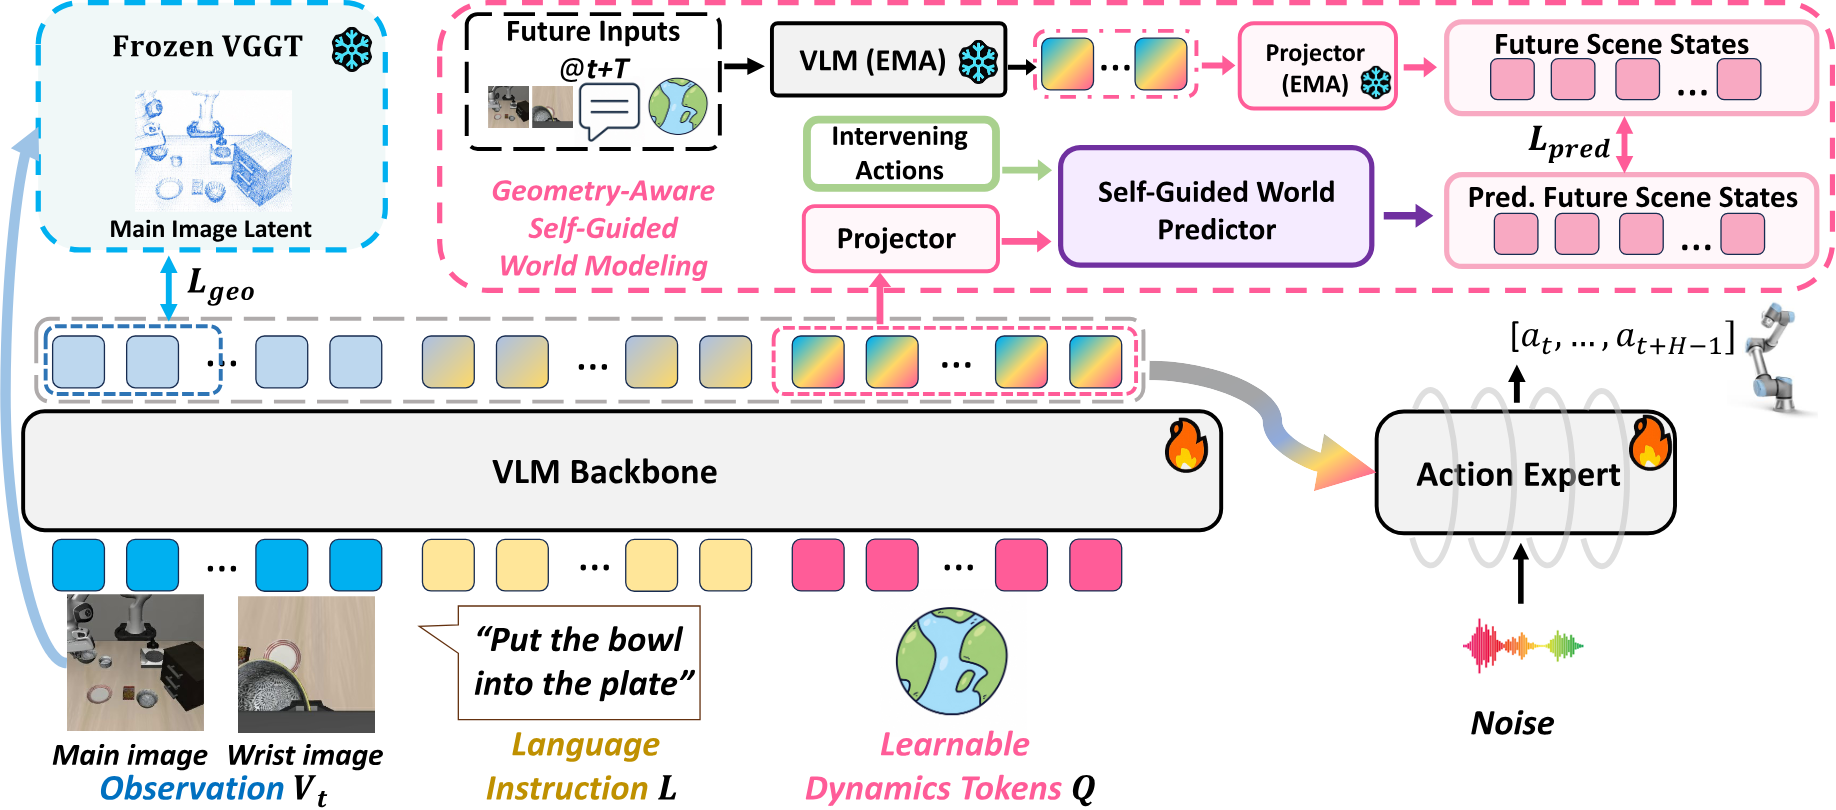
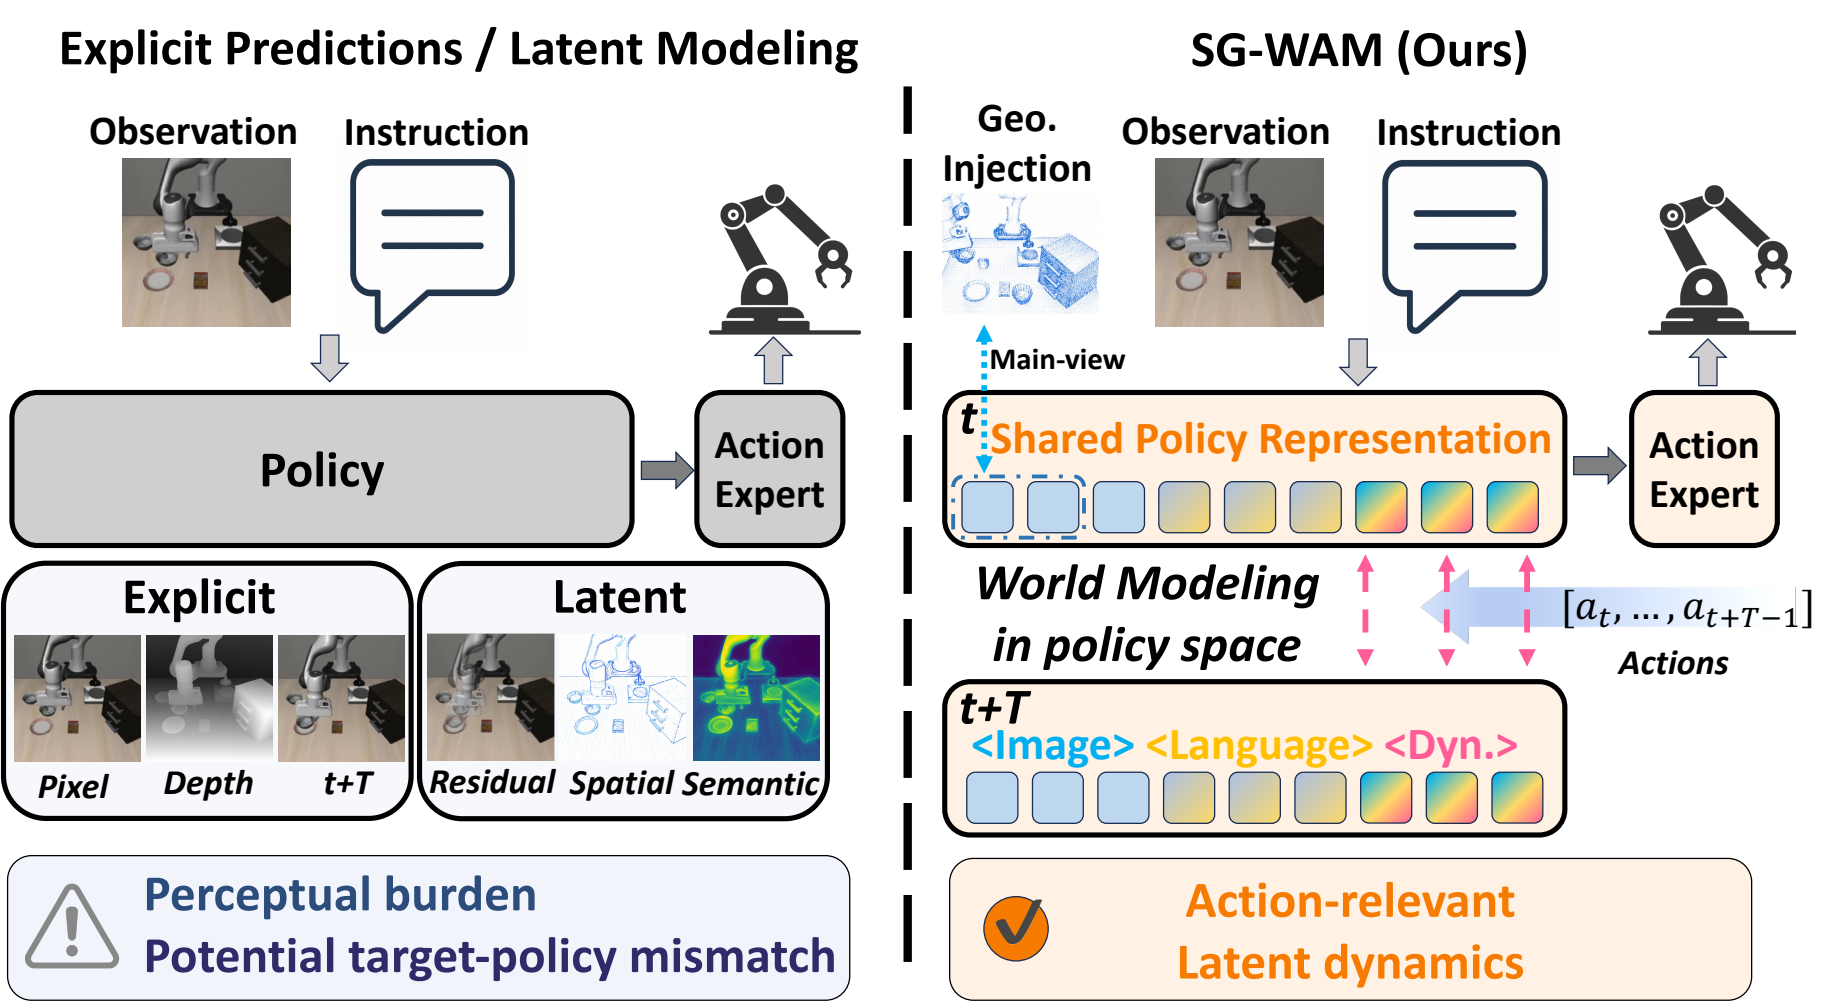
SG-WAM: Self-Guided World Modeling in Geometry-Aware Policy Space
Ruiteng Zhao, Zhengshen Zhang, , Wenshuo Wang, Jiahui Li, Zhiyuan Yang, Francis E. H. Tay, Marcelo H. Ang Jr., Haiyue Zhu†
SG-WAM predicts action-conditioned future dynamics in a geometry-aware policy representation space for robust robot manipulation.
Ruiteng Zhao, Zhengshen Zhang, , Wenshuo Wang, Jiahui Li, Zhiyuan Yang, Francis E. H. Tay, Marcelo H. Ang Jr., Haiyue Zhu†
SG-WAM predicts action-conditioned future dynamics in a geometry-aware policy representation space for robust robot manipulation.
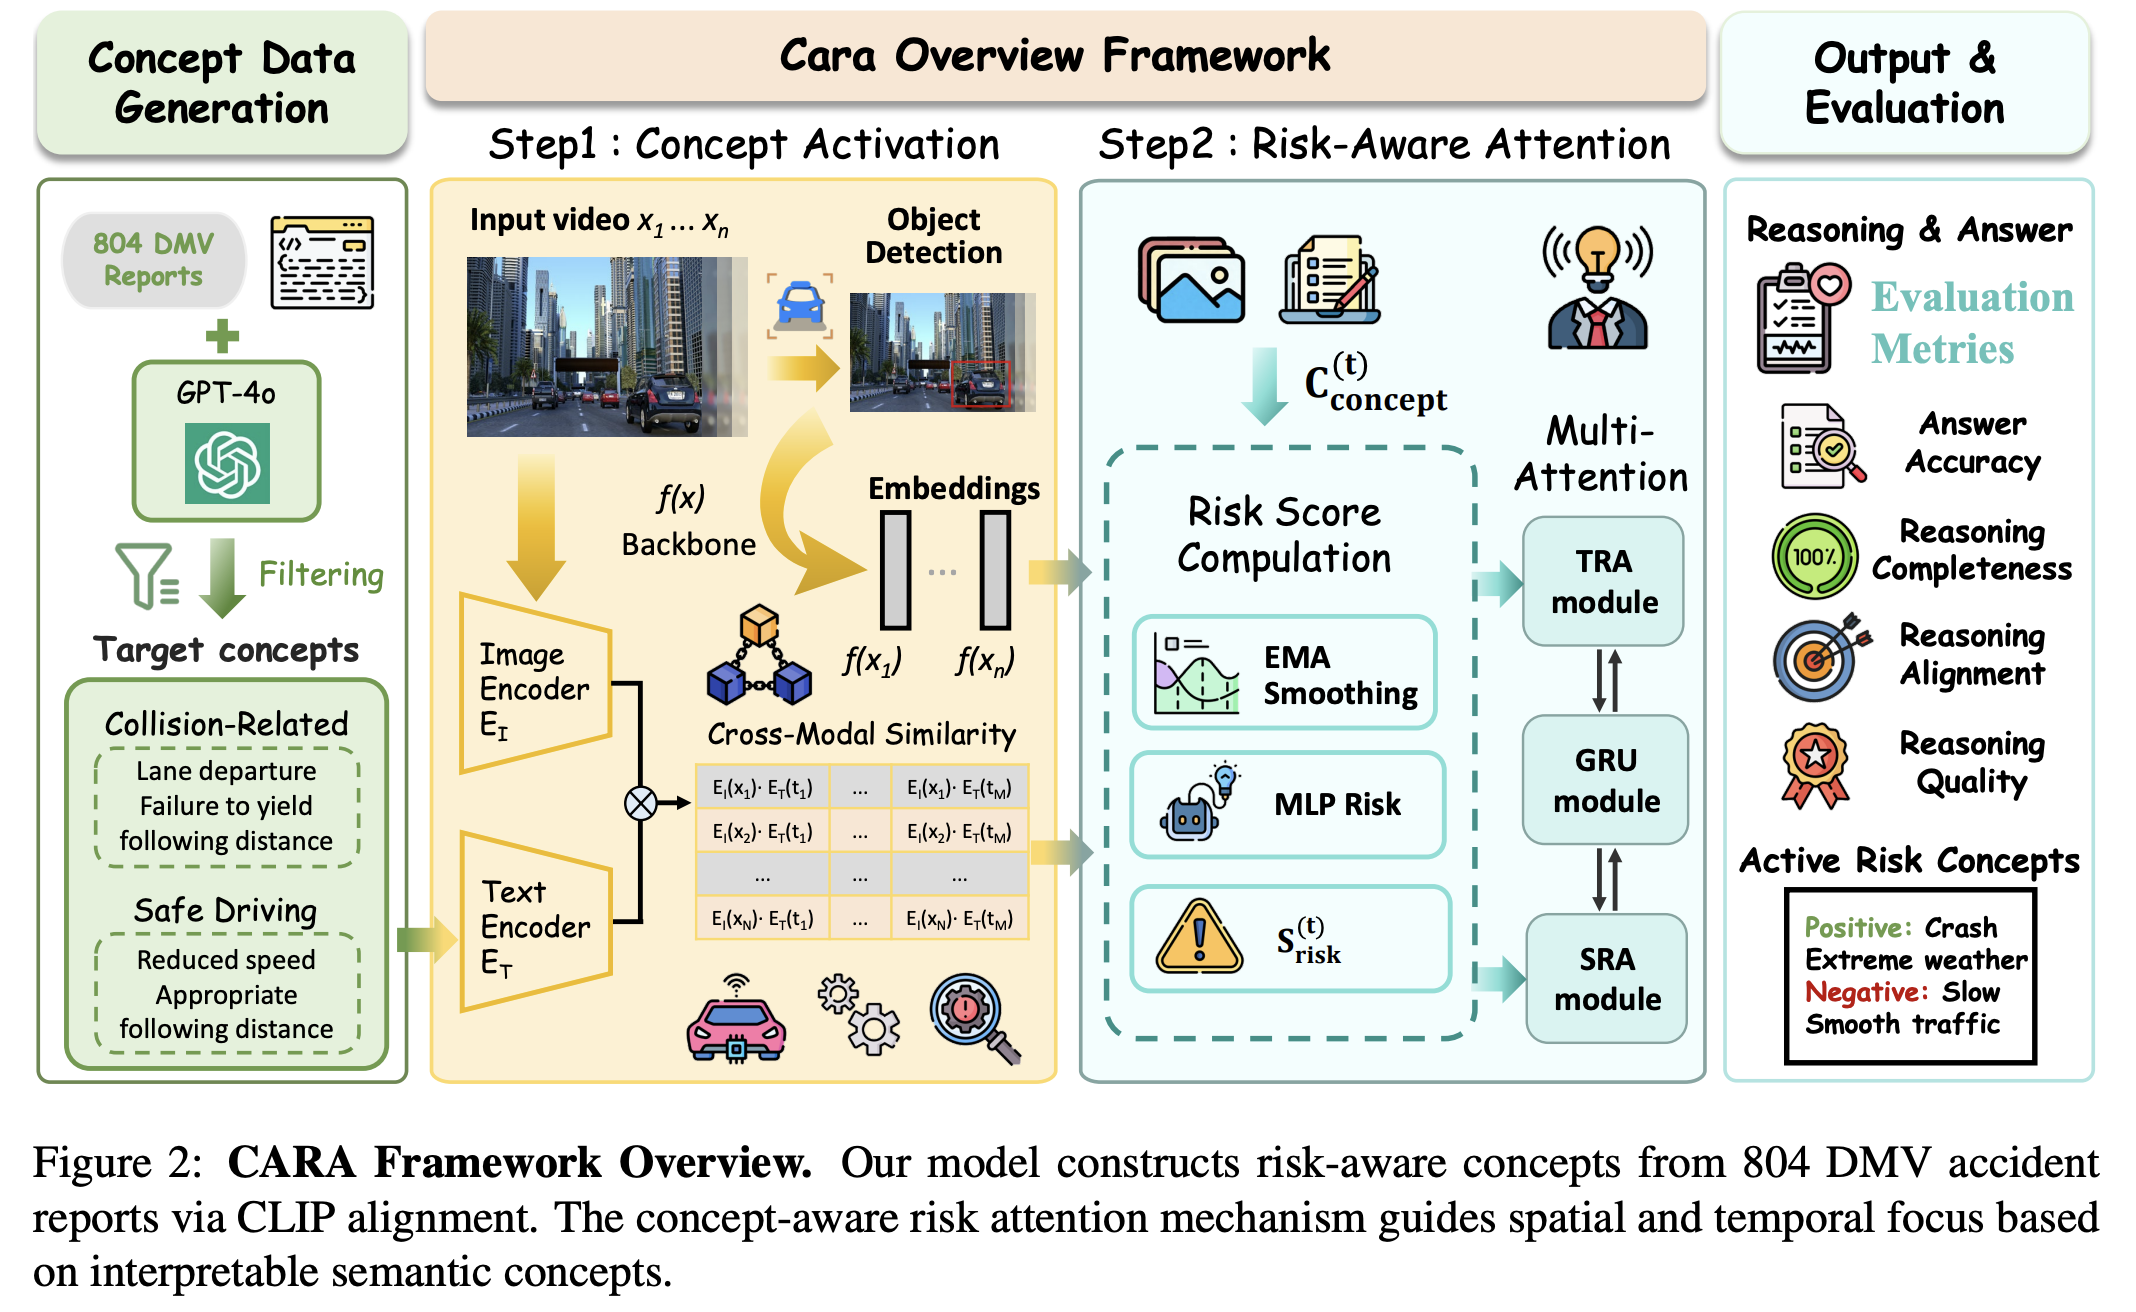
CARA: Concept-Aware Risk Attention for Interpretable Collision Prediction
Zhishan Tao, Ruoyu Wang, Yucheng Wu, Enjun Du, Yilei Yuan, Sherwin Ho, , Jinbo Su, Yi Hong†
An interpretable spatio-temporal framework that grounds collision prediction in evolving, human-understandable risk concepts.
Zhishan Tao, Ruoyu Wang, Yucheng Wu, Enjun Du, Yilei Yuan, Sherwin Ho, , Jinbo Su, Yi Hong†
An interpretable spatio-temporal framework that grounds collision prediction in evolving, human-understandable risk concepts.
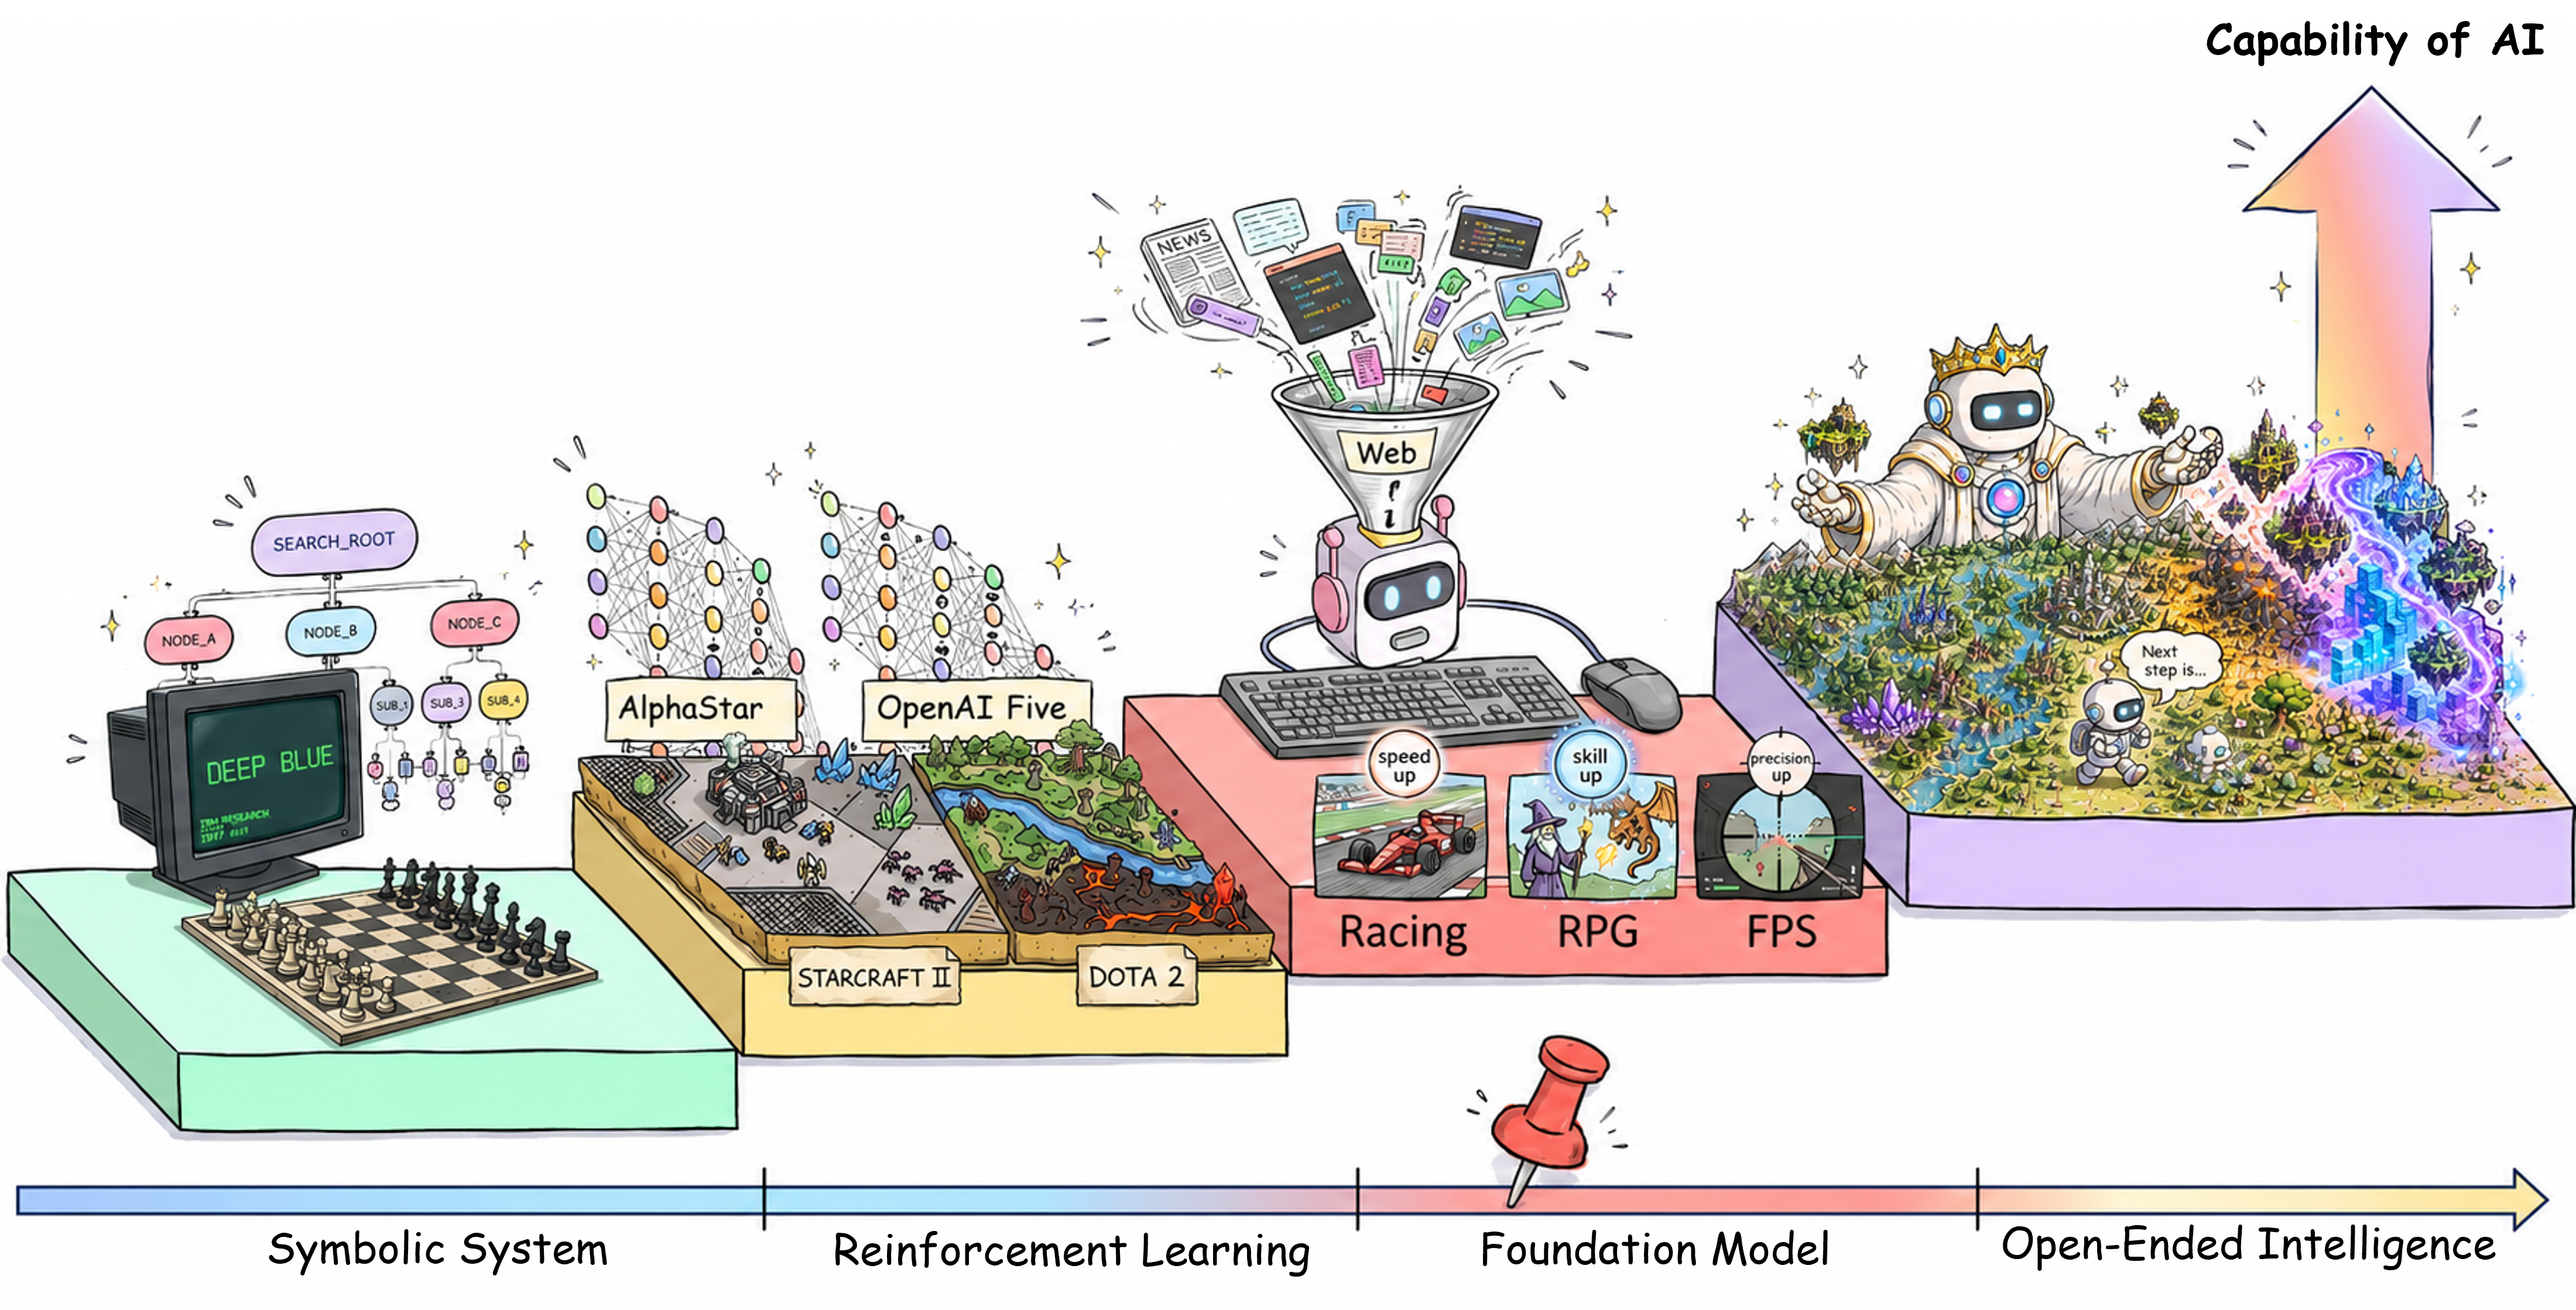
Towards Generalist Game Players: An Investigation of Foundation Models in the Game Multiverse
Kuan Zhang*, Dongchen Liu*, Qiyue Zhao*, Tianyu Xin*, *, Haisheng Wang, Han Yin, Hongbo Ma, Peize Li, ..., Yiming Li†
A survey of foundation models as generalist game players across datasets, models, harnesses, and benchmarks.
Kuan Zhang*, Dongchen Liu*, Qiyue Zhao*, Tianyu Xin*, *, Haisheng Wang, Han Yin, Hongbo Ma, Peize Li, ..., Yiming Li†
A survey of foundation models as generalist game players across datasets, models, harnesses, and benchmarks.
CLAP: Contrastive Latent Action Pretraining for Learning Vision-Language-Action Models from Human Videos
Chubin Zhang*, Jianan Wang*, Zifeng Gao, , Tiranru Dai, Cai Zhou,
Jiwen Lu, Yansong Tang†
Learning Vision-Language-Action Models from Human Videos.
Chubin Zhang*, Jianan Wang*, Zifeng Gao, , Tiranru Dai, Cai Zhou,
Jiwen Lu, Yansong Tang†
Learning Vision-Language-Action Models from Human Videos.
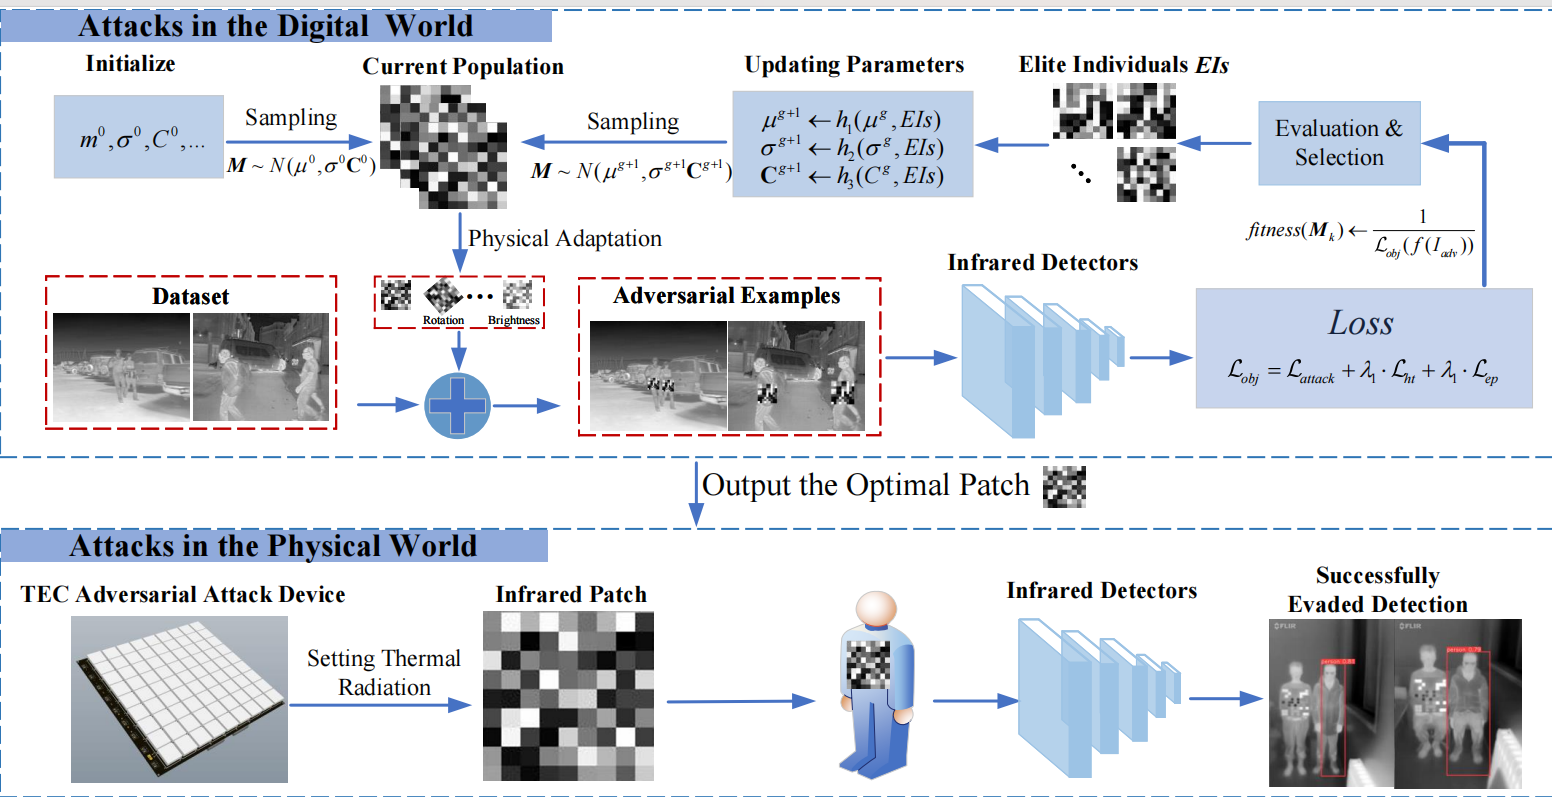
AdvDisplay: Adversarial Display Assembled by Thermoelectric Cooler for Fooling Thermal Infrared Detectors
Hao Li†, Fanggao Wan, , Yue Wu, Mingyang Zhang, Maoguo Gong†
Historically, infrared adversarial attacks were single-use and tough to deploy. Using TEC, we implemented efficient attacks adaptable to hardware scenarios.
Hao Li†, Fanggao Wan, , Yue Wu, Mingyang Zhang, Maoguo Gong†
Historically, infrared adversarial attacks were single-use and tough to deploy. Using TEC, we implemented efficient attacks adaptable to hardware scenarios.
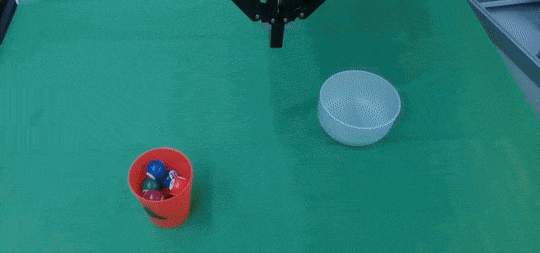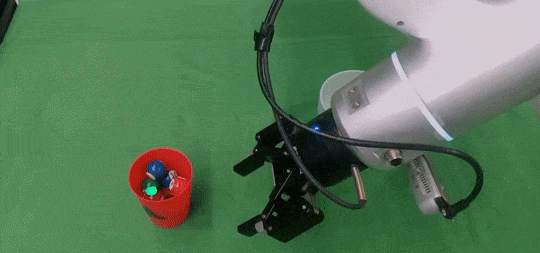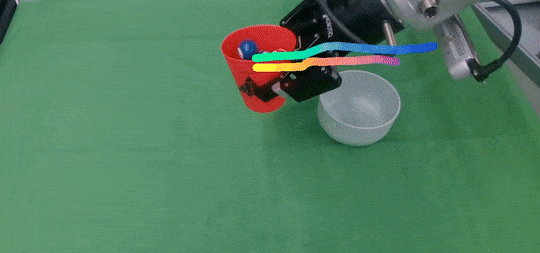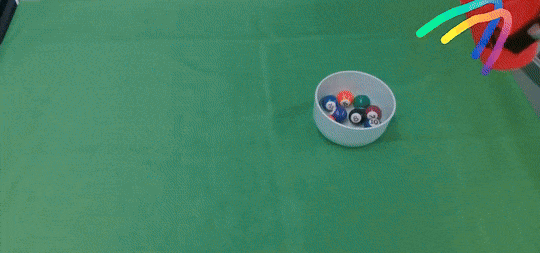
Motion Before Action: Diffusing Object Motion as Manipulation Condition
*, Xinyu Zhan*, Hongjie Fang, Yong-Lu Li, Cewu Lu, Lixin Yang†
Propose MBA, a novel plug-and-play module leveraging cascaded diffusion processes to generate actions guided by object motion, enabling seamless integration with manipulation policies.
*, Xinyu Zhan*, Hongjie Fang, Yong-Lu Li, Cewu Lu, Lixin Yang†
Propose MBA, a novel plug-and-play module leveraging cascaded diffusion processes to generate actions guided by object motion, enabling seamless integration with manipulation policies.
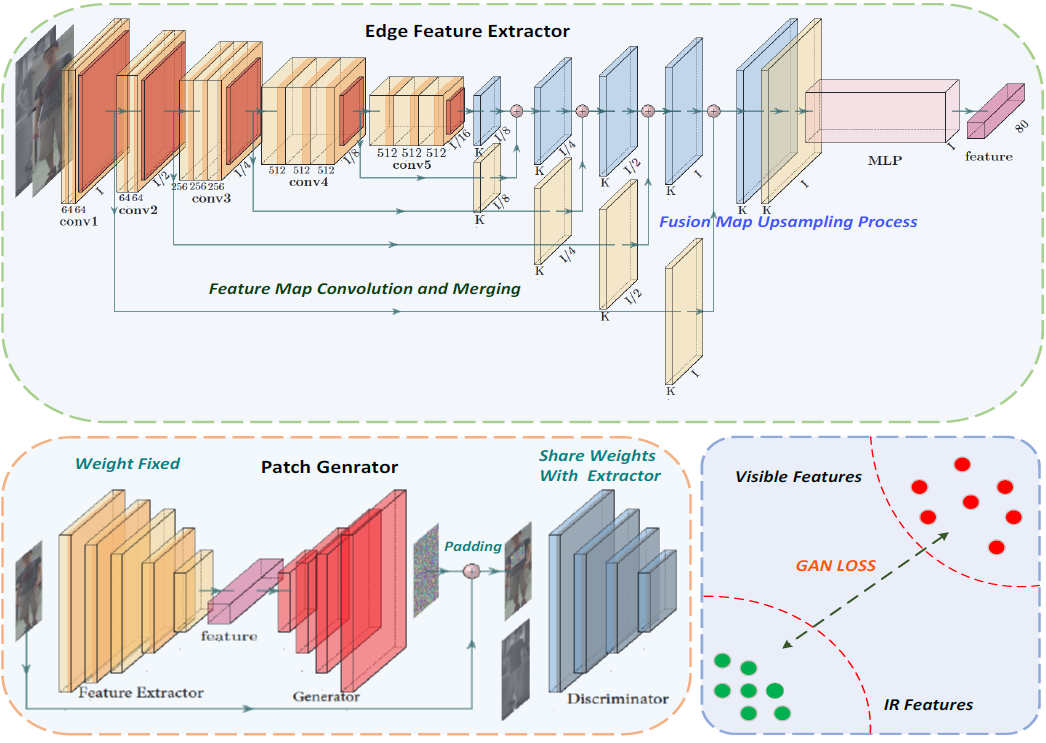
Generative Adversarial Patches for Physical Attacks on Cross-Modal Pedestrian Re-Identification
, Hao Li†, Maoguo Gong†
A generative physical adversarial attack on VI-ReID models perturbs modality-invariant features.
, Hao Li†, Maoguo Gong†
A generative physical adversarial attack on VI-ReID models perturbs modality-invariant features.
REPEAT. REFINE.
Aha Looped Transformer
An open visual atlas exploring looped Transformers, recurrent computation, adaptive depth, and latent reasoning.
An open visual atlas exploring looped Transformers, recurrent computation, adaptive depth, and latent reasoning.
ManiUniCon: A Unified Control Interface for Robotic Manipulation
ManiUniCon is a comprehensive, multi-process robotics control framework designed for robotic manipulation tasks. It provides a unified interface for controlling various robot arms, integrating sensors, and executing policies in real-time.
ManiUniCon is a comprehensive, multi-process robotics control framework designed for robotic manipulation tasks. It provides a unified interface for controlling various robot arms, integrating sensors, and executing policies in real-time.
Novels
Kindred· An AI simulated city
Blogs
Awards
- Xiaomi Outstanding Scholarship
- National Scholarship
- Outstanding Student